Control
Analytical Approach: Five Components of Control
The first control component is the controlled object itself, the system being controlled.
Denote the outputs of a certain system S by the symbol Y(t), and divide the inputs into externally controlled U(t) and uncontrolled, but observable V(t) (Figure 4.1). We know that there are inputs, unknown to us, but the unknown cannot be included in the model except through the notion of stochastic events: the observed values turn out to be random. Even so, the unknowm is not reflected by the fortuity of the known.
The allocation of controlled inputs means that we consider the system 5 as a controlled object. The outputs Y(t) are the result of the transformation of the system S inputs.
V(t) and U(t): Y(t) = S{V(t), U(t)), which allows you to act on Y(t) by selecting different controls U(t) (note that the symbols given are valid only for noninertial systems, although in reality the output of the system depends not only on the inputs at a given time but also on their history. However, for our purposes this is not yet significant).
The second mandatory component of the control system is the control purpose. In Chapter 2, we discussed in detail the concept of goal when considering the problem of the feasibility of all systems. We only recall that our goal concept includes not only the final desired state of the system (Г* Y*) but the entire desired path to it, Y*(t) (Figure 4.2). Recall also that no matter how hard we try to take into account all the limitations when formulating a purpose, it remains subjective: first, we took into account only what we know, and our knowledge is always limited; second, how exactly and how correctly we did it, that is, the result of our work, which inevitably bears the imprint of a person. So, the question of the actual attainability of the goal with the help of the S system remains open until the very beginning of the control process.
The control action U(t) is the third control component. The fact that the inputs and outputs of the system are interconnected by some relation Y(t) = S[ V(t), U(t)] allows us to hope that there exists such a control action U*(t), in which output implements the goal Y*(t):



FIGURE 4.2 The purpose is the entire path from problematic to ultimate goal states.
But how do you know if it really exists, and if so, what is it?
To do this, you need to solve Equation (4.1) with respect to U*(t).
In this equation, Y*(t) (given) and V(t) (observable) are known, but the operator 5 is usually unknown, which makes the problem unsolvable.
The solution is still to be found, and this leads to two types of control.
The first is to apply to the controlled input some kind of influence Ui(t) and see what happens. If the output is the goal T*(f), we are very lucky. If not, submit another impact Uj(t) and observe the result. To continue in this manner until the desired result is achieved, that is, look for the desired input U*(t) by sorting the effects on the system 5 itself.
Though sometimes this method is the only possible way (e.g., finding a way out of the maze), more often such a control method is unreasonable for several reasons. For example, the set of possible U(t) can be so large (and even infinite) that it is unrealistic to hope for an occasional successful hit. Another important reason is high losses in case of an incorrect decision. For example, S is a school, U(t) is a teaching method, and Y(t) is school graduates. It is clear that the search method is inappropriate here. Therefore, the search for the desired control action on the controlled object itself is often unreasonable and unacceptable.
The second approach is based on the use of all available information about the managed object. This implies that the search for the desired control should be carried out not on the system itself but on its model.
Thus, the system model becomes the fourth component of the control process. Instead of solving Equation (4.1), we now have to solve Equation (4.2) with respect to the control action Um*(t):
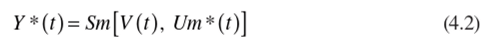
where F*(f), V(t) and Sm are known, that is, the model of the system. In principle (we will leave aside technical difficulties), such an equation can be solved. This will be rational and prudent control.
Of course, the search for control on the model also requires losses (the cost of the modeling process), but these losses are incomparably less than those we would have incurred looking for the right control on the system itself.
All actions necessary for successful control must be performed. This function is usually assigned to a specially created system for this (the fifth component of the control process), called the control unit or the control system (subsystem), control device, etc.
In reality, the control unit may be a subsystem of the controlled system (as the plant management is part of the plant, the autopilot is part of the aircraft), but it may also be an external system (as a ministry for the departmental enterprise, as an airport controller for landing an aircraft). There are complexities involved in constructing a model of composition, as discussed in Chapter 2.
So, the control system may look like it is presented in Figure 4.3, which shows all five components of the process of purposeful influence on a system.
We have now successfully established the first two mandatory steps of the control process (the model of structure of control):
- 1. find the required control action Um*(t) on the model of the system and
- 2. execute this effect on the system.
Stage of Finding the Desired Control Action
How to use the Sm model to find the best control action? Having used the evaluative word “best”, we must indicate precisely in what sense this evaluation is used, that is, to set quality criteria. It is clear that the control is “better” when the output of the system Y(t) is “closer” to the purpose Y*(t). But we’ll look for this control on the model, so at the control search stage, we’ll have to consider as the best Um*(t), which will maximally bring the output Ym(t) of the model to the purpose Y*(t).

If the outputs Ym(t) are measurable numerically, then some numerical criterion (“distance” between two functions) r = r (Y*(t), Ym(t)) is introduced, which would be zero if the compared functions coincide and increase for any of their differences. Such “distances” can be entered in many different ways. For example:
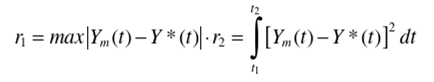
Having chosen some measure of difference between the two functions, we have to solve the problem of finding such Um*(t), w'hich delivers the functional r minimum (better, zero):
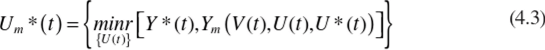
For the purposes specified non-numerically (in qualitative terms), methods of fuzzy logic still allow to introduce some evaluation of the proximity of the result to the purpose.

