Synthetic Approach to Control: Seven Types of Control
After applying the influence Um*(t) to the controlled input of the system, the system will produce some output process Y(t):
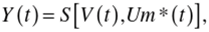
which is the transformation of the inputs by the operator S of the system. In this case, there may be different outcomes that require different actions to manage the system. This generates several different types of control.
The first type is simple system control or programed control.
Let’s start wfith the most desirable case, that is, w'hen the input of the system S is influenced by U„*(t), which provides the target Y*(t) at the output of the model Sm, leading to the same result at the output of the controlled system. This means that our S,„ model proved to be adequate as the S system obediently fulfilled the given purpose. In this case, the system S will be called simple. The simplicity of the system is a consequence of the adequacy of the model. The control action U,*(t) in this case is called a program, and this type of control is called a programed control.
Such a most favorable case can sometimes be realized in practice. Examples include serviceable household appliances, various automata, computers, weapons, an effective and dependable employee, an ideal soldier, etc.
The second type of control is the management of a complex system.
Consider another extreme case, w'hen the system S does not respond in the same way as the model to the control action Um*(t) found on the model: Y(t) does not coincide w'ith Y*(t). We denote this situation with the appropriate terminology.
Let’s start with the fact that our model did not allow us to achieve the goal; our S„, model is inadequate. System S behaves in an unexpected way and does not submit to our control (“this damn thing behaves not in the way it should be!”). We will call such a system complex. The reason for the complexity of the system with this approach is the inadequacy of its model Sm.
We emphasize that we have introduced a special definition of complexity. There are several other definitions, some of which are associated w'ith the concept of complexity with multiplicity and variety of the components, while others with the multidimensionality of control components and, especially, with the law of universal interconnection and interaction in nature. We will use the term “complex” only in the sense of insufficient information about the controlled object. From this viewpoint, complexity is not a property of the system, but a property of those who work with the system.
Obviously, the management of a complex system is reduced to obtaining the missing information about the system and the subsequent use of this information for the next control act. This means that we must improve the model of the system and enhance its adequacy.
We will proceed from the assumption that in building the Sm model we used all the available information about the system from textbooks, monographs, reference books, Internet, and experts. Thus, the only source of information remains the system itself, and the only way to extract this information is to experiment with the system.
Experiment is a question to the system, to which it gives an honest answer. We have already asked one question. By applying to the controlled input the impact we asked the system: “Honey, will you give out the impact on the output T*(0”? And she replied: “No, I’m not like that! I respond with the function Y(t)”. This received information should be included in the model by transmitting information through the feedback circuit, as well as changing and correcting the model so that it responds to Um*(t) with the same function Y(t) as the system (Figure 4.4). Now the Sm model has become more similar to the S system, at least in this example.
We use the new, revised, and augmented model Smi to search for the next control action (here we introduce in the diagram the index “Г of the next step i = 1, 2, ...), Such steps are repeated, which gradually improve the model and increase its adequacy.
Therefore, the control algorithm of a complex system is as follows:
- 1. At this i-th point in time, models Smi of system 5 are searched by some method (and methods can be different: random search, gradient descent, sorting out, etc.) and control action Umi*(t), which provides the target Y*(t) functions at the output of this model.
- 2. Impact Umi*(t) is fed to the controlled input of system 5.
- 3. The output of the system Yi(f) is observed and recorded.
- 4. If Yi(i) and Y*(t) differ, the model is corrected (due to its varying parameters) so that the corrected model Sm(i+I)is repeated as accurately as possible at its output, giving the system response Yi(t).
- 5. Return to point 1 (/ —■> i + 1).

FIGURE 4.4 Scheme of controlling a complex system.
Let us again discuss the features of the control algorithm of a complex system.
First, the algorithm has a cyclical and repetitive character. With each cycle Sm improves and becomes more adequate, which increases management efficiency and reduces the complexity of the system. In some cases, a complex system can be turned into a simple one in a finite number of steps. An example is the case when you forgot the cipher you dialed from an automatic camera. An improvement in the model consists in replacing its string “with number X may open” after unsuccessful sampling No. X with the string “with number X not opening”, and in a corresponding reduction in the number of remaining variants.
In other cases, the model is corrected by changing its parameters. For example, if a model is an equation, its coefficients change, indicators and members of the equation are added or eliminated, etc. If the model is a physical device, its settings, adjustments, switching, etc. also change. Sometimes these actions lead to a sufficient adequacy of the model, that is, they simplify the system.
However, there are systems whose complexity mankind cannot exhaust despite all efforts (nature, society, economy, thinking, etc.). This does not mean that their study is in vain, it is simply infinite. They are sometimes called very complex systems.
Second, since at each step “not quite the goal of will be obtained, we will suffer losses. Such is the price of ignorance. We can only minimize the inevitable losses in the management of a complex system.
This can be done only completely and w'ithout any loss using the information obtained in the next experiment (control step), that is, to make the adjusted model as accurately as possible to simulate the behavior of the system at each of the previous steps.
Now it is time to give a widely used name for this method, although with some reluctance because of linguistic peculiarities. While developing a professional terminology for the needs of the theory and practice of governance, each next control action was called a trial action or just a sample, and the discrepancy between Yi(t) and Y*(t) an error. The control algorithm of a complex system is called the trial and error method. Because of this terminology, some confuse it with “poke method”. The fundamental difference between them is that the desired effect is not sought on the system itself (in the “poke method”), but on the model of the system which is corrected in the course of control. We can say that the “poke method” is the worst method of managing a complex system, while “trial and error” is the best. But even in this case the loss is inevitable: for the ignorance you have to pay.
It is important to emphasize that even with the obvious infinity of knowledge of the very complex systems, progress is still possible by trial and error method; although the exact task of the final goal will have to be abandoned, it is possible to go in its direction, overcoming specific “today’s” obstacles and defining specific restrictions, within which there is freedom for trial and error.
The third type of control is parametric control or regulation. Consider the intermediate case between the first two.
By submitting Um*(t), we can observe that at first the system follows the desired trajectory but after a while there is a discrepancy between Y(t) and Y*(t) (Figure 4.5). Of course, this means that something is wrong with the model.
However, it often turns out that amending the model of the system is impractical. For example, a plane driven by an autopilot goes off course by a gust of wind. It makes no sense to introduce this impulse even into the model of the environment V(t) as it will not happen again. But we need to return the system on desired trajectory Y*(t). Now it is possible by making changes to the system itself.
The first possibility is to change the system parameters without changing its structure. The parameter is changed so that the system returns to the target trajectory, and at further deviations of Y(t) from Y*(t) this action is repeated. A good example is driving a car. The target trajectory is the right side of the road (in England, Japan, and other countries on the left). The driver changes the position of the steering wheel (and other adjustable parameters of the machine), holding the car on the target trajectory (Figure 4.6).
To implement this type of control, you must perform the following functions:
- 1. keep the reference trajectory Y*(t) in memory;
- 2. follow the real trajectory Y(t)


FIGURE 4.6 The full cycle of regulation.
- 3. detect the current difference between Y(t) and Y*(t);
- 4. develop, determine, and calculate the corrective additional to Um*(t), as well as the impact on the parameter^) of the system;
- 5. perform this action on the system, returning it to the reference trajectory.
To perform these functions, you must create a special device, an additional system. This device is called the regulator, and the method of control is called regulation. The control scheme now looks different (see Figure 4.7, and compare it with Figure 4.3). The regulator is represented by a square “R”. It is placed on the scheme at a position that allows it to be attributed either to the system itself, to the system controlling, or to be considered as an independent system. It is important to perform these functions, and where they will be physically performed depends on the circumstances. For example, the control of the aircraft on different parts of its trajectory can be performed by an autopilot, a pilot, or an aerodrome dispatcher.
If the software control is called control without feedback, the regulation control is a negative feedback (emphasizing the desire to reduce the deviation from

the reference path; with positive feedback, the deviation tends to increase, as, for example, in oscillators).
To implement the regulation, it is necessary that the system deviates from the reference trajectory not too quickly and not too far, so that, by changing the parameters, it can be returned to the target trajectory Y*(t). In the mathematical theory of regulation, this condition is called “small” deviations.
Unfortunately, this condition is sometimes not satisfied. For example, the car can go to the icy section of the road, and no manipulation of the wheel and brakes will be able to keep it on the road. We find ourselves in an environment where a different type of control is required.
The fourth type of control is control by means of changing structure. When the system deviates so quickly and so far from the target trajectory that it cannot be returned to it by changing the parameters, we have two options: pessimistic and optimistic. Pessimistic means humility before the impossibility of achieving the ultimate goal, and sometimes even death. Optimistic is associated with recognizing the facts and making an attempt to achieve (T*, Y*) by some other means. The fact is that this goal is unattainable for the existing system. But maybe it is achievable for another system?
Change the structure of the system at the moment Ts (Figure 4.8), thus creating a new system, with the hope to arrive at the point (T*, Y'*) even if on a different trajectory Ys*(t). This control is called the control by means of changing the structure. You can distinguish between cases where the new structure is created only from parts (perhaps not all) of the old system, and cases of involvement in the structure of new elements from the outside.
Various options meet the multiplicity of names for this type of control: reorganization, modernization, restructuring, self-organization, etc. As examples, we can cite surgery, change the administrative management scheme, ballast discharge from the balloon, intake or blowing water from submarine tanks, extension to the building, prosthetics, etc.
It is clear that we can meet the case when no combination of available elements ensures the achievement of the ultimate goal. This means it is impossible and inappropriate to control by structure, the potential of which is exhausted.

The fifth type of control is control by purposes. The output is again seen not in hopeless lowering arms, and to recognize the fact and make an optimistic conclusion. The fact is that no use of the limited means and resources available can realize the desired state: this purpose in these conditions is unattainable.
It remains to change the purpose, lowering the level of claims, and to refocus on achievable deadlines and (or) other parameters of the final state. This is the fifth way of control, that is, control by purposes.
It is possible to distinguish the purposes that are unattainable in principle. The detection of the unattainability of some of these goals is a reason to abandon the desire for them.
There are, however, other obviously unattainable goals, but attractive and worthy aspirations for them, and most importantly, by allowing unlimited approach to them; such goals are called ideals (harmoniously developed personality, absolute sports superiority, knowledge of the truth, absolute good, etc.), and people spend a lot of energy to strive for these goals.
There are goals that are unattainable in some conditions, but achievable in others; there are goals, the achievability of which is desirable, but not proven, although not refuted (artificial thinking, antigravity). There are also goals that are achievable but not achieved because of ineffective or erroneous governance. However, in some cases, determining w'hich of the options we are faced with is not easy.
In the practice of governance by objectives this is quite common, especially in the administration and management: rotating personnel, offering feasible jobs, retraining, and other methods of personnel management. It should only be borne in mind that the change of purpose for any individual is a painful process, the more difficult the higher the level of the purpose has to be changed (awareness of the unattainability of the goal can sometimes even make the subject’s life further meaningless). So, this method requires caution.
The sixth type of control is the control of large systems. The first two types are based on improving the system model, the third and fourth on changing the system itself, and the fifth on changing the purpose. There is another factor that affects the quality of control and requires a new way of doing it. This is the timeliness of the control action. The statements “The train has already left”, “Where were you yesterday?”, “Strong back mind”, “Wit on the staircase”, “The ship has sailed”, “No use crying over spilt milk”, “It’s easy to be wise after the event”, and “You’ve missed the boat” display a folklore fact of the futility of belated decision, even the best one in all other respects.
The delay in choosing the best possible solution is caused by the fact that to evaluate each of them you need to “play” it on the model of the system, and this requires some time. However, the time allowed to develop a solution may be limited: after this time, management becomes meaningless. It is necessary to operate in real time and to model management in an accelerated manner.
It may turn out that the time required to find the optimal solution exceeds the maximum allowable for executing the control intervention. Then the very opportunity to find the optimal solution becomes superfluous. This is necessary to operate and requires developing another method of management.
We will now frame a situation with which we are faced with special terms. The system for finding the optimal impact on which there is enough information resource (the model is adequate), but not enough time to sort out all of it, we will call a large system, otherwise a small system.
For example, we can cite the Soviet economy when the intersectoral balance was brought with a delay of three to four years. (In the centralized economy of a huge country, it was necessary each year to maintain a balance between millions of produced and consumed products.) It was believed that this is one of the main reasons for the low efficiency of economic management in the country.
Another example was given at the time by the Novosibirsk Academy computer center, which implemented a very developed multicomponent model for accurate weather prediction for the day ahead, but the power of the then computer center made it possible to obtain a forecast only in a few days.
It is clear that the reason that the system turns out to be large is not the magnitude itself, that is the bulkiness of the system, but the insufficient speed of search and comparison on the model of control options, that is, the lack of time.
Therefore, the first and the most effective way to control a large system is to turn it into a small one, speeding up the modeling process. For example, replacing the modeling computer with a faster one, parallelizing the optimization algorithm, delegating parts of manager’s powers to assistants, etc.
However, this method can encounter insurmountable difficulties (e.g., there are no more powerful machines, there were no suitable personnel, there is not enough finance). Therefore, in real practice, timely decision-making gives the result. Not the best, but a timely decision is better than no or belated decisions. We need to abandon the expectations of obtaining the optimum variant and to receive the first of the resulting satisfactory. Often to obtain a weak but fast solution we turn to various simplifications of the model (dimension reduction, linearization and other simplifying approximations, rounding of exact numbers, etc.). This accelerates tackling of a difficult situation for the manager, acting under the time constraints._Sometimes, however, behind this lies the inability to work better.
The seventh type of control is control under unknown ultimate goal. In addition to the first type of control, when everything necessary for the implementation of the goal is available, the rest of the control types are associated with overcoming the factors that prevent achieving the goal: lack of information about the control object (the second type), small difference between real environment V(t) and its model Vjt), slightly deviating system S from the target trajectory (the third type), the discrepancy between the emergent properties of the system and the goal (the fourth type), the lack of material resources, making the goal unattainable and requiring its replacement (the fifth type), and the lack of time to find the best solution (the sixth type). All these cases are based on the assumption that the end is known.
However, in real life, there is another situation: when it is necessary to control current events, but the ultimate purpose is incomprehensible and unknown.
How to govern if you are deprived of the opportunity to specify the ultimate goal? In this case, we go to the seventh type of management — control in the absence of information about the ultimate goal.
From the definition of the purpose adopted by us in Chapter 2, it is logical that the uncertainty of the final goal is followed by the uncertainty and the trajectory of movement to it. However, the control actions for any type of control are aimed at moving along this path with the maximum achievable proximity to it. This aspiration can be realized in at least two ways in this situation.
The first is to give a subjective, a priori definition of the ultimate goal, and then act on the previous schemes.
A clear (but not the only) example of this gives us the governance of large social systems. What is the meaning of life? What is the purpose of social development? Ideologies give ready answers to this. However, these answers are only hypotheses.
Different communities adhere to different ideologies by subjectively giving preference to one or another ideal. History has already shown the lifelessness of some of them (slave and feudal system), has revealed the acute shortcomings of others (tyrannical, dictatorial regimes), and has utopian character of thirds. We are witnessing the decline of society toward the ideals of liberal democracy. But even in democratic ideology, some fundamental goals are contradictory. For example, the ideas of equality and freedom are incompatible: freedom is impossible with equality, and equality is impossible with freedom. The attempt of the French revolution to unite them with the help of “brotherhood” looks naive or in any case unconstructive. The applied systems analysis offers in this case one more ideal — equality and equivalence of each individual and improving intervention as a way of realization of this ideal (see Chapter 1).
An interesting option for implementing the democratic ideal (majority decisionmaking) is a two-party system. One party gives priority to freedom, while the other to equality. Both ideals are attractive, but incompatible. Society elects “socialists”, that is, begins to realize equality (in particular, carries out nationalization of large branches of economy and realizes social projects). However, the process of equalization inevitably constrains the initiative of the subjects, and the development of society slows down. When this becomes obvious and undesirable, society elects “liberals” who start privatization and unleash personal initiative through freedom and private property. This accelerates the development of the economy, but increases inequality between the rich and poor segments of society. This causes an increase in tension in society, as well as in the sense of “injustice”. Here and there is an opportunity to elect a party to power, preaching equality. A concrete example is England with its Labor and Tory parties.
The fact that this is a manifestation of some more general system regularity gives an example of optimizing the smoothness of the trajectory of the TU-154 heavy transport aircraft, as studied by Professor Y. I. Paraev of Tomsk State University. Aircraft flaps can be put in any position between the two extremes. It turned out (this is a strict mathematical result!) that the optimal control of such an inertial system as an aircraft consists in switching the flaps from one extreme position to another, that is, at correctly selected points in time. No intermediate position! There is a clear analogy with the two-party system. Maybe that’s why the world is drifting multiparty systems in the direction of bipartisanship?
Yet, let us recognize that any social ideology that affirms its vision of the ultimate goal actually offers a hypothesis, the truth of which is a matter of faith in it and subsequent verification in practice.
There is, however, a different approach to management if the ultimate goal could not be clearly defined, but it is hoped that it exists. If this is the case, then there must be a trajectory to it. It is also unknown, but you can try to explore the nearest neighborhood around the current state and determine the most preferred direction of the next step within that neighborhood. Then take that step and act in the future as well.
This method is actually implemented in various areas.
In biology, this is called evolution and natural selection. In management theory (understood broadly), it is called incrementalism (making small but necessarily improving changes). In the mathematical theory of optimization, several ways of finding the extremum of the function of several variables (coordinate steps such as the Gauss- Seidel method, random search, the method of the steepest descent along the gradient, etc.) are proposed. In social systems, we have already mentioned Kautsky criticized by Marxists with his slogan “the goal is nothing, the movement to it is everything”.
Of course, success is not guaranteed on this path. The objective function, the existence of which we are sure, can have several extremums, and we can get not in the global, but in the local extremum (e.g., dead-end branches of the evolution of living populations; the choice of satisfactory, not optimal solutions in the management of social systems; stuck in local extremums in mathematical optimization).
One gets the impression that the only absolutely universal purpose of the existence of any system is its very existence (“the meaning of life is in itself’). Only after surviving, the system can begin to pursue some (any) other goals.

